Current Issue

2026 Vol. 26, No. 9

The Others
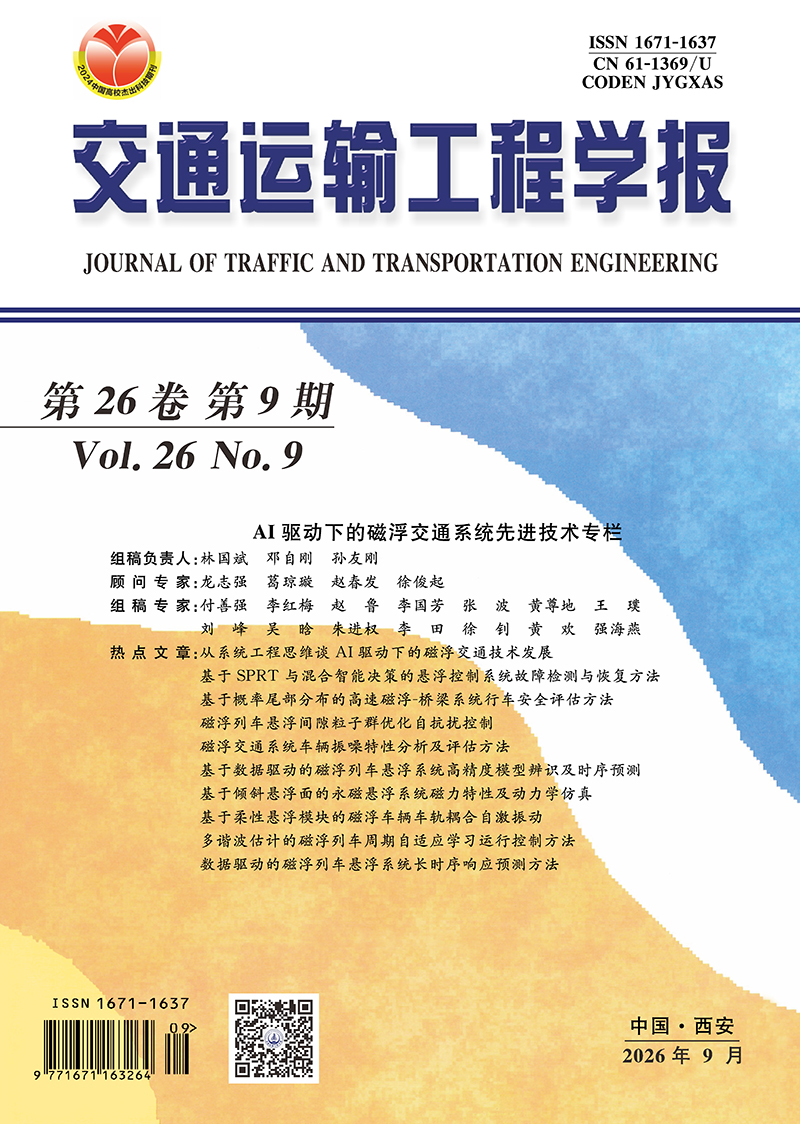
Cover and Contents of Vol.26, No.9, 2026
2026, 26(9): .
Special Column of AI-enabled Advanced Technologies for Maglev Transportation Systems
Discussion on the development of maglev transportation technology driven by AI from the perspective of systems engineering thinking
XIONG Jia-yang, SHEN Zhi-yun
Abstract:

The integration path and practical effectiveness of artificial intelligence (AI) with maglev transportation technology were explored from the perspective of systems engineering thinking to tackle the complex control and management challenges arising from the coupling of multiple subsystems in maglev transportation and promote its upgrading towards intelligence and efficiency. Firstly, at the theoretical level, the core characteristics of different technical routes of maglev transportation were analyzed, and the technical logic of AI adapting to the core contradiction of "dynamic uncertainty and high precision control" in maglev transportation was clarified. Meanwhile, the internal mechanism of AI realizing subsystem collaborative optimization under the guidance of systems engineering thinking was explained, and the systems engineering value of AI in constructing an intelligent closed-loop system of "perception, decision, control, optimization" was defined. Secondly, in five core subsystems including suspension guidance, traction transmission, the power supply system, signal communication, and intelligent operation and maintenance scheduling, the technical breakthroughs and scene adaptability of AI algorithms such as the BP neural network, LSTM, and reinforcement learning were elaborated. Additionally, the improvement effect of AI technology on suspension accuracy, traction efficiency, power supply stability, and signal reliability was quantitatively analyzed, and the full-dimensional empowering effect of AI on maglev systems was verified. Thirdly, an AI empowerment path of "top-level data specifications, software and hardware iterative verification, compound talent cultivation, and cross-domain collaborative innovation" was proposed, and the technical development context of medium-low speed, high-speed and ultra-high speed vacuum pipeline maglev was sorted out, with the engineering practice results under different scenarios summarized. Finally, existing challenges were analyzed, such as data silos, insufficient reliability in extreme operating conditions, disconnections between industry, academia, research and application, shallow integration of AI with emerging technologies, and lack of cross-industry collaborative mechanisms. The future development direction was proposed from five aspects of full-domain data fusion, robust model R&D, deepening of collaborative innovation mechanisms, integration of emerging technologies, and intelligent collaboration for cross-industry multimodal transportation. The results indicate that the deep integration of AI and maglev transportation technology under the guidance of systems engineering thinking is the core support for solving the multi-subsystem coupling difficulties of maglev systems and realizing the leap from high speed to intelligence, and its subsystem collaborative optimization mechanism provides a theoretical paradigm and practical guidance for the intelligent development of maglev transit.

More>
2026, 26(9): 1-11. doi: 10.19818/j.cnki.1671-1637.2026.329
Fault detection and recovery method of suspension control system based on SPRT and hybrid intelligent decision-making
SUN You-gang, ZHANG Zeng, GAO Ding-gang, XU Jun-qi, MENG Chuan-shu
Abstract:

A full-state fault detection algorithm incorporating hybrid decision-making and reset logic was proposed to address the problem that the probes of maglev train air gap sensors are prone to failure in special operating conditions including strong magnetic fields, vibration, and rail joint crossing. By adopting fault identification, signal switching, and fault-tolerant strategies, system stability in special operating conditions was ensured. Firstly, the suspension control system based on a joint structure was taken as the research object to carry out system dynamics modeling, and the coupling relationship and stability between the left and right electromagnets were analyzed. Secondly, a new method capable of rapidly identifying faults and implementing timely fault tolerance was proposed by integrating a full-state feedback control algorithm based on a signal selection strategy, sequential probability ratio test (SPRT), and residual chi-square detection. Simulation results show that in cases where some sensor probes fail, the initial fault detection time is delayed by 0.02~0.2 s after fault occurrence. The missed detection rate during the fault duration is approximately 5%. For sensor probe faults of varying severity degrees, the proposed fault-tolerant control strategy reduces the average fluctuation of the left electromagnet to 0.27 mm and the right electromagnet to 0.13 mm. The SPRT algorithm advances the response time to fault termination by about 0.5 s, enabling rapid detection and recovery. In rail gap crossing conditions, faults can be identified instantly, and the fluctuation of the suspension gap is significantly suppressed by approximately 89%~91%. The proposed method significantly enhances the robustness and fault tolerance of the suspension control system against gap sensor probe failures, ensuring the dynamic stability and ride comfort of maglev trains under long-term service.

More>
2026, 26(9): 12-25. doi: 10.19818/j.cnki.1671-1637.2026.249
Driving safety assessment method for high-speed maglev-bridge systems based on probabilistic tail distribution
YU Hao-wei, ZHOU Zi-ji, LIN Hong-song, YANG Guo-jing
Abstract:

In response to inaccurate safety assessments in high-speed maglev-bridge systems due to the neglected cumulative train operation effect of the traditional methods, a probabilistic safety assessment method based on the tail distribution of driving safety indicators was developed. A high-speed maglev-track bridge coupled stochastic dynamic model was established using the square power good lattice point method, multibody dynamics, and the modal superposition method. The probabilistic characteristic parameters of driving safety indicators (mean and standard deviation) were determined using the equal probability method and extreme-value theory. An explicit mapping relationship between the probabilistic characteristic parameters and the extreme-value cumulative distribution function (CDF) was constructed. According to a predefined confidence level, the extreme-value estimate of the safety indicator was obtained. By comparing this with the current normative threshold, a driving safety assessment method based on the probabilistic tail distribution characteristics was proposed. Finally, taking the case of a high-speed maglev train passing over a 24.768 m track beam, a driving safety assessment was conducted under different operating conditions such as varying train speeds. The results indicate that by employing the square power good lattice point method to construct a highly uniform set of track irregularity samples, the computational requirements can be met with only 131 samples. Compared to the 5 000 samples required by the Monte Carlo method, this significantly improves both the computational efficiency and accuracy of the probabilistic characteristic parameters for driving safety indicators. Furthermore, the extreme-value distribution proposed can effectively characterize the tail distribution characteristics of driving safety indicators. Its distribution curve well fits the maximum value samples, and the estimated extreme values can fully envelope the results generated by the Monte Carlo method. The number of failed samples evaluated based on the tail distribution model is less than 10, whereas it is as high as 2 280 under the normal distribution assumption. The method effectively avoids the limitation of traditional methods in failing to account for the cumulative effect of train operations, thereby providing a scientific basis for the safety assessment of high-speed maglev-bridge systems.

More>
2026, 26(9): 26-34. doi: 10.19818/j.cnki.1671-1637.2026.252
Particle swarm optimization based active disturbance rejection control for maglev train suspension gap
LI Chuan-jian, WU Shan-shan, ZHANG He-hong, LONG Zhi-qiang
Abstract:

To address such issues as uncertain internal and external disturbances, open-loop instability, and the difficulty of controller parameter tuning in the electromagnetic suspension systems of maglev trains, a suspension gap control method was proposed active disturbance rejection control (ADRC) based on particle swarm optimization. The internal disturbances (e.g., model linearization errors, parameter perturbations) and external disturbances (e.g., track irregularities, sudden load changes) were treated as a unified total disturbance. An extended state observer was employed to estimate and compensate for them in real time. While the dynamic linearization of the system was achieved, a novel integrated discrete time-optimal control function was designed, and the corresponding tracking differentiator was established to enhance signal tracking performance. In response to the difficulty in manually obtaining optimal solutions for key parameters such as observer bandwidth and controller gain in the active disturbance rejection controller, the particle swarm optimization algorithm was introduced. By constructing a multi-objective fitness function incorporating the integral of absolute error and control energy consumption, the global optimization was carried out for controller parameters to balance the fast tracking capability and the noise suppression ability of the system. The research results demonstrate that under conditions of suspension startup, sudden load changes, and random track noise, the proposed method exhibits significant performance advantages over traditional manually tuned ADRC. The settling time during the startup process is significantly shortened with no overshoot. Under sudden applied load disturbances, the cumulative absolute error of the suspension gap is reduced by 28.3%, and a steady state can be recovered more rapidly. Furthermore, in a noisy sensor environment, the control voltage curve remains smooth without high-frequency chattering. This method effectively resolves the conflict between the rapidity and disturbance rejection of the maglev system, and realizes the optimal tuning of control parameters, providing an effective technical solution for the stable suspension of maglev trains under complex operating conditions.

More>
2026, 26(9): 35-45. doi: 10.19818/j.cnki.1671-1637.2026.333
Vibration and noise characteristics analysis and evaluation methods for maglev transportation system vehicles
CONG Jian-li, WEI Zi-long, YANG Fei, SUN Xian-fu
Abstract:

A scheme for detecting and evaluating vibration and noise data of maglev vehicles was proposed, and the self-developed portable on-board device was employed to collect vibration and noise data of maglev vehicles at low cost and high frequency. The attitude deviation of the inertial sensor coordinate system was corrected, and the vibration characteristics of maglev vehicles were analyzed. The running quality of maglev vehicles was evaluated by adopting the ISO 2631-1:1997 weighted acceleration, Sperling ride-comfort index, and A-weighted sound level, and the speed and mileage information from the measured data were autonomously estimated. The results show that the vertical correction angles of the on-board device for the Shanghai and Changsha maglev systems are 0.08° and 0.95°, respectively, and the horizontal correction angles are 0.82° and 3.45°, respectively. The dominant frequencies of longitudinal and lateral car-body vibrations for both systems are within 10 Hz, while those of vertical car-body vibration are within 40 Hz for the Shanghai maglev system and within 30 Hz for the Changsha maglev system. The sampling frequency meets the detection requirements. For the Shanghai maglev system, the maximum ISO 2631-1:1997 weighted acceleration is 0.9 m·s-2, with exceedance ratios of 95.5% for level Ⅰ and 71.1% for level Ⅱ. The maximum Sperling ride-comfort indexes for lateral and vertical directions are 2.64 and 2.73, with level Ⅰ exceedance ratios of 0.96% and 69.8% respectively. The maximum A-weighted sound level is 73.8 dB(A), and the ratio exceeding 70 dB(A) is approximately 78.2%, indicating that the running quality of the vehicles in the Shanghai maglev system is good. For the Changsha maglev system, the maximum ISO 2631-1:1997 weighted acceleration, Sperling indexes for the lateral and vertical directions are 0.26 m·s-2, 2.32, and 2.15, respectively, all below the level Ⅰ limits, which indicates that the running quality of maglev vehicles in the Changsha maglev system is excellent. Visualizing various evaluation indicators in the longitude-latitude coordinate system of the maglev line intuitively reflects the along line distribution of the maglev vehicles' running quality. This method can provide data support for the maglev track operation and maintenance department to precisely regulate the service status of maglev tracks at different mileage locations.

More>
2026, 26(9): 46-60. doi: 10.19818/j.cnki.1671-1637.2026.334
Data-driven high-precision model identification and time series prediction for maglev train suspension systems
GAO Ding-gang, BAI Zheng-qi, ZHANG Le, SUN You-gang
Abstract:

In response to low modeling accuracy and poor robustness in the suspension control systems of EMS-type maglev trains caused by high dimensionality, strong nonlinearity, and open-loop instability, a high-precision model identification and time series prediction method was proposed based on a long short-term memory (LSTM) improved by the Bayesian optimization (BO) algorithm. First, an experimental platform for a single-degree-of-freedom magnetic suspension system was built. A controller was used to track complex excitation signals, including sine, pulse, and white noise. Time series data of the control voltage and suspension gap covering the dynamic characteristics of the system were collected. The input and output sequences were reconstructed using the sliding window method. Second, an LSTM model was constructed to capture the time-dependent features of the suspension system. In response to the difficulty of manual parameter tuning in balancing efficiency and performance, the BO algorithm was introduced. A Gaussian process was selected as the probabilistic surrogate model, and the expected improvement was used as the acquisition function. The mean absolute error of the model on the validation set was set as the objective function. A global optimization was performed for the number of hidden layer neurons, initial learning rate, and L2 regularization coefficient of the LSTM model. Research results show that after BO, the model can accurately predict the key state changes of the suspension gap. The prediction error stabilizes within ±0.1 mm, and the error distribution conforms to a normal distribution, indicating that the structural deviation of the model is eliminated. Compared with the unoptimized LSTM model, the mean absolute error on the test set is reduced by 48.04%, and the root mean square error is decreased by 41.83%. This method effectively solves the difficulty of hyperparameter setting in suspension system modeling, and significantly improves the prediction accuracy and generalization ability of the model, providing a reliable model foundation for the design of high-precision suspension controllers and real-time condition monitoring of maglev trains.

More>
2026, 26(9): 61-73. doi: 10.19818/j.cnki.1671-1637.2026.250
Magnetic force characteristics and dynamics simulation of permanent magnet suspension system based on inclined suspension surface
MA Ya-qun, XU Ao-kang, MA Wei-hua, LI Miao, LU Jing, LUO Shi-hui
Abstract:

A concise structural scheme of sideslip suppression was proposed for an inclined suspension surface. By adopting a passive structural design, the scheme realized sideslip suppression by virtue of gravity component force and additional lateral force, with no additional complex active control components required and high engineering feasibility. In the research, the calculation models of suspension force and lateral force for the inclined suspension surface were derived based on the equivalent magnetic charge method. A 3D magnetic field finite element analysis (FEA) model was established with small-size N45H permanent magnets and verified by bench tests. A full-scale FEA model was constructed, in which five transversely arranged Halbach arrays of permanent magnets were deployed on both the vehicle and track sides. Combined with the multi-body dynamics model of a single vehicle, simulation analyses were carried out under the straight-line condition of 60 km·h-1 and the small-radius curve condition of 20 km·h-1. Research results show that after the magnetic force characteristics analysis, the inclination of the suspension surface has a weak influence on suspension force, with a maximum variation amplitude lower than ±1 kN, and produces a significant promotion effect on lateral force. The maximum lateral force at an inclination angle of 10° increases by 153% compared with that at 0°. Under the straight-line condition, the inclination angle of 9.5° reduces the fluctuation of suspension force of permanent magnet pairs by approximately 19.59%, improves the contact stability of guide wheels, and significantly reduces the lateral offset. During curve passing, the amplitude and fluctuation of suspension force decrease, while the amplitude and fluctuation of lateral force increase slightly. The lateral positioning accuracy of vehicles is optimized, and the sideslip is effectively suppressed. The regulation law and engineering design interval of inclined suspension surfaces are clarified, providing theoretical basis and data support for the structural optimization, parameter matching, and engineering application of permanent magnet suspension transportation systems.

More>
2026, 26(9): 74-87. doi: 10.19818/j.cnki.1671-1637.2026.330
Self-excited vibration of maglev vehicle track coupling based on flexible suspension module
LI Hai-tao, ZHANG Wen-yue, LIN Guo-bin, HONG Yuan-zhuo, CHEN Chen
Abstract:

In response to the high-frequency coupled vibration between the vehicle and track occurring during vehicle suspension, the formation mechanism and suppression methods of coupled self-excited vibration were systematically studied, taking into account the flexible characteristics of the suspension module and track structure. A rigid-flexible coupled multi-degree of freedom system dynamics model characterizing the flexible characteristics of the electromagnet and the F-rail was established based on the Euler-Lagrange method. The influence law of control parameters and structural parameters on the stability of the coupled system was analysed using multimodal eigenvalue method. Furthermore, a self-excited vibration energy analysis method based on periodic energy balance was developed to explore the contribution of each parameter under critical instability conditions. The coupled self-excited vibration mechanism of the suspension module and the F-rail was revealed from the perspective of energy input, dissipation, and transfer. Simulation results show that the self-excited vibration may be caused by either the dominant mode of the electromagnet or that of the F-rail. In terms of structural parameters, the stability of the closed-loop system can be improved by appropriately reducing the electromagnet length, decreasing the support stiffness of the F-rail, and increasing the span of the F-rail. Self-excited vibration dominated by the flexible mode of the electromagnet is highly sensitive to its first-order bending mode parameters and the installation position of the suspension sensor on the electromagnet. By introducing modal damping compensation control or optimizing the sensor arrangement, the coupled vibration in a specific frequency band can be effectively suppressed, which has certain significance in engineering guidance.

More>
2026, 26(9): 88-106. doi: 10.19818/j.cnki.1671-1637.2026.331
Periodic adaptive learning operation control method for maglev trains using multi-harmonic estimation
RUAN Yu-xin, PAN Si-min, YUE Qiang, ZHANG Wen-jing
Abstract:

A model reference periodic adaptive learning control method based on multi-harmonic resistance estimation (MH-MRAC-PALC) was proposed according to the periodic operation characteristics of maglev trains on fixed routes to improve the operation control position and speed tracking accuracy of maglev trains. The designed composite controller consists of three parts: feedback control, feedforward control, and the multi-harmonic resistance estimation compensator. Meanwhile, based on Lyapunov stability theory, the parameter update rate of the estimation compensator was designed. By integrating real-time data of the current cycle and historical cycle operation information, online estimation and dynamic compensation of the operating resistance were achieved with the MH-MRAC-PALC controller. Based on the maglev test line, numerical simulation was conducted, and comparative analysis between the designed controller, conventional PID controller and MH-MRAC controller was carried out. The simulation results show that after 20 cycles of learning, the position tracking performance of the MH-MRAC-PALC controller is significantly improved, its root mean square error (RMSE) is reduced from 0.076 4 m in the first cycle to 0.006 9 m, and the maximum error is reduced from 0.254 8 to 0.027 4 m. Additionally, the speed tracking RMSE is reduced from 0.035 6 m·s-1 to 0.002 9 m·s-1, and the maximum error is reduced from 0.104 7 to 0.012 2 m·s-1. In comparison, the position and speed RMSEs of the PID controller are 0.633 6 m and 0.076 3 m·s-1, respectively, and those of the MH-MRAC controller are 0.085 3 m and 0.040 1 m·s-1, respectively. After 20 operation cycles of learning, the MH-MRAC-PALC controller can accurately estimate the multi-harmonic resistance. In complex working conditions with unknown resistance and slope disturbance, the controller exhibits stronger anti-interference ability and higher tracking accuracy. Compared with traditional PID control and MRAC control, the MH-MRAC-PALC control method achieves accurate resistance estimation, reduces the position and speed tracking errors, and significantly improves the operation control performance of maglev trains through the periodic learning mechanism.

More>
2026, 26(9): 107-116. doi: 10.19818/j.cnki.1671-1637.2026.251
Data-driven long-term response prediction method for maglev train suspension systems
CHEN Zhang-hang, XU Jun-qi, LIANG Xin, NI Fei
Abstract:

To overcome the error accumulation problem in long-term prediction of dynamic responses of high-speed maglev train suspension systems, a data-driven response prediction method was proposed without requiring explicit dynamic differential equations. Two improvements are proposed on the basis of the deep unknown equations (DUE) flow map learning framework. First, a state-disturbance decoupling strategy was adopted. Track irregularity was treated as a known external input and concatenated with state variables at the network input, while state variables were predicted alone at the network output. Error propagation through the disturbance channel was thus fundamentally eliminated. Second, an initial-state anchoring mechanism was introduced. Real observations from the initial segment of the trajectory were used as fixed anchor points and continuously injected into the network input. A global reference baseline free from prediction error contamination was thereby provided for the recursive chain. The single-point suspension system of an electromagnetic suspension type high-speed maglev train was taken as the study object. Validation was conducted under two excitation scenarios, namely, ideal track irregularity and measured track irregularity. The results show that the prediction curves of the DUE baseline model exhibit obvious drift and divergence as the number of recursive steps increases. After the introduction of state-disturbance decoupling and initial-state anchoring, the improved scheme achieves a reduction of over 80% in all error metrics compared with the baseline under the ideal track irregularity scenario. Ablation experiments demonstrate that state-disturbance decoupling serves as the fundamental safeguard against recursive divergence, while initial-state anchoring effectively suppresses the cumulative error caused by the decay of initial information. The two strategies exhibit clear functional complementarity. Under the measured track irregularity scenario, the mean relative error of prediction is still kept within 4%. Good statistical consistency is also demonstrated under different initial conditions and disturbance sequences. The proposed method can provide a new approach for rapid dynamic response prediction of high-speed maglev suspension systems without relying on explicit dynamic equations.

More>
2026, 26(9): 117-129. doi: 10.19818/j.cnki.1671-1637.2026.332
Transportation Infrastructure Engineering
Research progress on multi-scale evaluation method for loose defects of asphalt pavement in airports
QU Xin, HAN Chang, ZHANG Yan, WANG Hai-nian
Abstract:

Airport asphalt pavements were susceptible to loose particle removal under high tire pressures, severe impact, intense torsional shear, and water-temperature-loading coupling. However, the existing evaluation methods were predominantly derived from the highway sector, with insufficient applicability to airports. In response to these issues, the research progress on multi-scale evaluation methods for asphalt pavement loose defects was systematically reviewed. Based on the differences in service conditions between airports and highways, the mechanisms of interfacial adhesion failure, cohesion failure within the transition zone, and cohesion failure within the asphalt mastic associated with loose defects were analyzed. At the macroscale, evaluation methods were summarized, including static-water moisture-stability testing, dynamic-water scouring, and simulations of torsional-shear and impact loading for asphalt mixtures. At the mesoscale, the bonding performance of asphalt-aggregate interfaces characterized by adhesive mechanical tests and surface free energy theory was reviewed. At the micro- and molecular scales, the application of atomic force microscope and molecular dynamics simulations in analyses of interfacial morphology, nanomechanics, and microscale surface energy was summarized. At the full scale, the roles of field evaluation techniques, such as ground penetrating radar and in situ pull-off testing, as well as accelerated loading devices, in investigating the overall loose defect of pavements were assessed. The analysis results indicate that loose defect is a multi-scale coupled deterioration process resulting from the combined effects of intrinsic material properties and multiple external factors. Although macroscale tests facilitate engineering-level screening, it is difficult to reproduce the distinctive service conditions of airports. Meso-, micro-, and molecular-scale methods help elucidate interfacial failure mechanisms, but quantitative correlations with macroscale material loss and field defects remain insufficient. Full-scale evaluation is closer to actual service conditions but is constrained by cost, efficiency, and environmental interference. Future research should develop multifactor coupled simulation devices specifically for airport pavements and establish cross-scale correlation models linking microscopic interfacial energy, mesoscale bonding strength, macroscale material-loss severity, and full-scale in-service behavior.

More>
2026, 26(9): 130-154. doi: 10.19818/j.cnki.1671-1637.2026.348
Force transfer performance of chambers in steel-concrete joint section of railway composite beam cable-stayed bridge
CHENG Gao, ZHOU Guang-jin, LI Wei, MENG Xiang-jian, WEN Qiang, KANG Wei, WEN Bo-hua, LIU Yong-jian
Abstract:

To investigate the force transfer mechanism and mechanical properties of these joint sections, a single-cell chamber of a joint section from a railway composite cable-stayed bridge was selected as the research object. By eliminating the front bearing plate and embedded steel beam section from the preliminary design of the actual bridge, a theoretical formula for shear transfer length was derived. Based on this theoretical formula, a single-cell test model with a scale ratio of 1∶2.5 was designed and constructed. The stress distribution, load-bearing capacity, and force transfer characteristics of the joint section under axial compression conditions were analyzed. A finite element model was established to investigate the force transfer mechanism, load-bearing performance, and accuracy of the shear transfer length formula under varying parameters. Results indicate that two equal shear transfer lengths exist within the joint section, determined solely by the axial compression stiffness of steel and concrete, along with the stiffness of the continuous spring layer at the interface. The model's load-bearing capacity reaches six times the equivalent bearing capacity. The measured surface stress distribution and axial force transfer ratio exhibit rapid changes at both ends while stabilizing in the middle. Shear connectors at both ends demonstrate high utilization rates, with measured shear transfer length values deviating no more than 5% from theoretical values. According to the influence analysis of force transfer mechanism parameters, the variation patterns of force transfer ratios and relative slip under different parameters align with experimental measurements, with the force transfer mechanism remaining fundamentally consistent. The finite element values for shear transfer length exhibit less than 20% deviation from theoretical values. Changes in bearing plate thickness and joint section length have no effect on shear transfer length. The factors influencing shear transfer length are chamber width, chamber height, perforated steel plate thickness, and others, ranking from greatest to least in impact. The difference in connection group utilization rate across varying joint section lengths can reach 15%. The utilization rate influence ranking of relative slip and connection group is as follows: joint section length, chamber width, chamber height, and others. In design, the joint section length should be appropriately selected. Additionally, the density of shear connectors at both ends can be increased while the number in the middle can be reduced to enhance utilization rate.

More>
2026, 26(9): 155-174. doi: 10.19818/j.cnki.1671-1637.2026.174
Characteristics of sudden cable fracture and train-bridge coupled vibration of highway-railway cable-stayed bridge
WANG Tao, BAI Lun-hua, WANG Lu, ZHANG Xing-biao, ZOU Xu-wei
Abstract:

To investigate the impact of sudden cable fracture accidents on the safety of bridge structures and running trains under operational conditions for highway-railway cable-stayed bridges, a train-bridge coupled vibration calculation program based on the explicit nonlinear finite element dynamic algorithm was developed. A three-dimensional full-bridge finite element model of an actual long-span highway-railway cable-stayed bridge was constructed. The completed bridge state under dead load was calculated by using the static nonlinear finite element method. By using the explicit nonlinear finite element method, the dynamic response of the bridge structure under continuous fractures of multiple stay cables was calculated. The positions of the fractured stay cables after falling and colliding with the main girder were calculated and analyzed. Furthermore, the dynamic responses of the bridge and train under a sudden cable fracture were calculated under different train-bridge coupled vibration conditions. The results indicate that the explicit finite element method can simply and intuitively simulate the cable fracture damage of cable-stayed bridges, possesses advantages in both accuracy and efficiency in the calculation of train-bridge coupled vibration, and has better technical applicability. The cable-stayed bridge structure has a high safety redundancy, and the remaining cables can effectively share the load after a cable fracture. The main girder may collapse only in an extreme case where more than 10 continuous stay cables fracture on one side. Under the action of a transverse wind with a speed of 30 m·s-1, the fractured stay cable is prone to fall onto the upper deck of the main girder. After the fracture of a single stay cable, trains can maintain passage. At the moment of fracture of the longest stay cable 34# at the mid-span, the vertical and transverse displacements of the main girder change abruptly and significantly, and the vertical acceleration of the main girder jumps to approximately 20 m·s-2. When a train travels on the bridge at a speed of 200 km·h-1, and the longest stay cable 34# on the right side of the mid-span suddenly fractures, under extreme conditions, the maximum wheel load reduction rate reaches approximately 0.91, and the maximum derailment coefficient reaches approximately 2.73 within a short period of time. The main girder vibration caused by the cable fracture exposes the train to an obvious derailment risk. The research results can provide a reference for the safety assessment of cable-stayed bridges when cable fracture accidents occur.

More>
2026, 26(9): 175-190. doi: 10.19818/j.cnki.1671-1637.2026.013
Real-time monitoring method for bolt loosening in railway hump retarders based on top-down strategy
XU Peng, QIN Zhi-jian, YANG Yong-han, SHAN Xiao-nian, WANG Wen-fei, ZHANG Zi-jun
Abstract:

To achieve automated and accurate monitoring of bolt loosening states in railway hump retarders under complex operating conditions, including continuous impact vibration, weather variations, and occlusion caused by passing trains, a real-time monitoring method for bolt loosening in railway hump retarders based on a top-down strategy was proposed. A three-stage collaborative process comprising detection, localization, and calculation was adopted. Accurate localization of bolt surface regions was achieved using the RTMDet model. Six corner points of each bolt were then identified within the detection box using the RTMPose model. An algorithm including geometric validity determination, perspective distortion correction, and angle normalization based on symmetry constraints was further proposed. The algorithm was used to quantitatively calculate the rotation angle and determine the bolt state. To verify the effectiveness of the method, high-definition camera equipment was deployed at a railway marshalling yard. A bolt image dataset was constructed under various weather conditions, including sunny, cloudy, rainy, snowy, and hazy conditions, and at different times of day, including morning, evening, and night. The dataset also included images with localized oil contamination and from multiple viewing angles. Comparative experiments were performed to evaluate the proposed method. Research results show that the proposed method achieves an accuracy of 95.1% and a recall of 93.8%. For bolt corner-point localization, the method achieves a root-mean-square error of 1.25 pixels and a coefficient of determination of 0.952 for rotation-angle estimation, with an average processing time of 28.3 ms per frame. The method demonstrates good robustness and generalization ability under varying installation angles, occlusion conditions, and illumination conditions, with angular errors below 1°. The proposed method provides a feasible technical solution for high-accuracy, real-time visual monitoring of bolt loosening in complex railway environments. This approach can be applied to intelligent operation and maintenance systems and condition monitoring systems for critical railway equipment, such as retarders and turnouts in marshalling yards.

More>
2026, 26(9): 191-206. doi: 10.19818/j.cnki.1671-1637.2026.270
Vehicle Operation Engineering
Two-stage model for heavy-duty truck fuel consumption prediction based on incomplete data
DU Kai, DENG Yu-xuan, HE Yan-ming, SONG Jing-ni, CHEN Dan
Abstract:

To address uncertainty and accuracy loss in heavy-duty truck fuel consumption prediction under missing-data conditions, this study proposed an end-to-end two-stage deep learning model for incomplete data scenarios. First, a continual adversarial imputation method combined Transformer-based feature extraction with a generative adversarial network, so that the generated data distribution closely matched the real distribution. Next, a fuel consumption prediction model integrated regional attention and pure graph attention mechanisms. Joint local and global modeling improved representation of complex dynamic features, enabling accurate fuel consumption imputation and prediction. Experiments on a real-world heavy-duty truck fuel consumption dataset with missing rates from 0 to 40% validated the proposed model. Research results show that, across different missing rates, the imputation mean squared error (MSE) ranges from 0.873 to 0.906, and overall performance surpasses seven baseline imputation methods. Impact analysis reveals that local dynamic variables, such as vehicle speed and acceleration, significantly affect fuel consumption imputation and prediction, whereas global factors, such as altitude and mileage, have a weaker effect. This indicates that local features contribute more to performance improvement. Comparative experiments demonstrate that the proposed two-stage imputation-prediction framework achieves the highest predictive accuracy, with an MSE of 0.602 0. Ablation experiments further confirm the effectiveness of each functional module. This study provides technical support for heavy-duty truck fuel management, carbon emission monitoring, and intelligent fleet scheduling, especially under complex operating conditions with incomplete data.

More>
2026, 26(9): 207-218. doi: 10.19818/j.cnki.1671-1637.2026.216
Electric vehicle fires in ro-ro ships and influence of ventilation based on numerical simulation
QIAO Jian, WANG Yan-fu, WANG Yi-ru, ZHANG Hao-ran, LIU Jing-xian
Abstract:

To explore the influence laws of different ventilation schemes on lithium-ion battery vehicle fires in ro-ro spaces, based on the temperature data and gas products from full-scale fire experiments, the equivalent material of lithium-ion battery vehicles was designed, the combustion equation of the equivalent material was derived, and an equivalent model of lithium-ion battery vehicle fires was constructed and verified. A partial area of the single deck on a car carrier ship was intercepted. With the position, height, and number of ventilation openings as variables, multi-vehicle fire simulations were conducted. The variation laws of fire heat release rate and temperature under different ventilation schemes were mainly analyzed, and the influence mode of ventilation on the heat distribution in the cabin was discussed. The analysis results indicate that the fire can be divided into three stages according to the heat release rate: the initial stage, the rapid development stage, and the intense combustion stage. In the initial stage of the fire, the main way for the fire to expand is to ignite surrounding combustibles, and the expansion of the fire area is the main factor leading to the increase in the heat release rate. In the rapid development stage of the fire, most vehicles have been ignited, and the deepening of the combustion degree of the ignited vehicles is the main factor causing the rise in the heat release rate. By comparing the fire development trends under different ventilation methods, it is found that ventilation has a dual effect on fire development: Ship ventilation can restrict the rate of combustion spread, but at the same time, it provides oxygen to the fire, resulting in more intense combustion. In the initial stage of the fire, ventilation restricts the diffusion of heat, prolongs the ignition time of surrounding combustibles, and inhibits the expansion of the fire. However, in the rapid development stage of the fire, ventilation provides more sufficient oxygen for combustion, thus promoting the development of the fire. Among various ventilation schemes, the lower ventilation and the ventilation directly facing the fire site carry the greatest risks. This paper can provide theoretical support for the ventilation design and fire prevention and control of car carrier ships.

More>
2026, 26(9): 219-232. doi: 10.19818/j.cnki.1671-1637.2026.025
Transportation Planning and Management
Multilayer network-based resilience evaluation for China-Europe container sea-rail intermodal transport systems
ZHANG Xin, MAO Jing
Abstract:

A resilience evaluation model from a multilayer network perspective was proposed to quantitatively analyze the resilience evolution law of the sea-rail intermodal transport system under different disturbance scenarios and recovery strategies. Based on real-world data of trains and shipping routes, a China-Europe sea-rail intermodal container transport network was constructed. Connectivity and transport efficiency were employed as evaluation indicators of system resilience, and a resilience simulation model considering different node recovery timings and recovery priorities was developed to simulate the resilience evolution law of the China-Europe sea-rail intermodal network. Heterogeneous influences of different disturbance scenarios on system resilience were revealed. Without recovery strategies, the network exhibits weak interference resistance under targeted attacks, and failures of a few critical hub nodes cause substantial decline in overall efficiency, with the network's resilience indicators lower than those of dedicated rail or sea networks. Under random failures, the network demonstrates strong interference resistance, with resilience indicators exceeding 0.8. Implementing recovery strategies significantly enhances the disturbance resistance of the network. However, a critical threshold exists for recovery timing. When the recovery timing of the failed node exceeds this threshold, system recovery costs increase exponentially and overall recovery time extends significantly. Distinct recovery strategies yield differential effects. Under targeted attacks, prioritizing node recovery based on degree centrality provides the greatest system resilience improvement, while prioritizing node recovery based on betweenness centrality achieves the lowest recovery cost intensity. The findings reveal the resilience evolution law of the China-Europe sea-rail intermodal transport network and provide a theoretical basis for enhancing the resilience of intermodal transport systems under emergencies and disasters.

More>
2026, 26(9): 233-245. doi: 10.19818/j.cnki.1671-1637.2026.072
Method for allocation of loading and unloading equipment in container rail-water intermodal hub
GAO Yun-feng, LIU Ke-jiang, CHEN Xiang-yi
Abstract:

To improve the efficiency of loading and unloading equipment allocation in rail-water intermodal transport container terminals and to reduce carbon emissions generated by container truck operations, a multi-objective combinatorial optimization model was developed considering the spatiotemporal characteristics of container flows and the rail-ship arrival under a hybrid handling mode of rail-water direct transfer and rail-yard-water operation. The optimization objectives were to minimize equipment operating costs, the turnaround times of trains and ships, and carbon emissions from container truck movements. A dynamic zone-based allocation strategy was proposed for container trucks. A discrete time-period equipment allocation mechanism was also introduced. The allocation numbers of quay cranes, rail-mounted gantry cranes, rubber tyred gantry cranes, and container trucks were dynamically determined. A genetic algorithm based on time-period allocation rules was designed to solve the model. The model was validated using 24-hour operational data from a rail-water intermodal transport container terminal. The results indicate that, in the original case, when the loading and unloading time windows of trains and ships overlap, the proportion of rail-ship direct transfer reaches 82%, the utilization rates of quay cranes, rail-mounted gantry cranes, and rubber tyred gantry cranes increase by 15%-20%, and the workload of rubber tyred gantry cranes in the export container yard and railway import container yard decreases by 15% and 23%, respectively. It proves that rail-ship direct transfer is the preferred transshipment mode for rail-water intermodal transport, which can significantly improve the utilization rate of terminal handling equipment, with significant impact of direct transfer capacity on the rubber tyred gantry cranes in railway import container yards. When the number of container trucks allocated to the direct-transfer zone reduces from 8 to 2-4 units, the total cost increases by 1.2%-2.8% and carbon emissions from container truck movements rise by approximately 16%, which indicates that both total cost and carbon emissions are highly sensitive to direct transfer capacity. Furthermore, under a large-scale handling scenario involving 5 ships and 4 trains, equipment operating costs account for 84.12% of the total cost, whereas this proportion increases to 87.8% when the handling scale is reduced to 1 ship and 1 train. This suggests that the proposed dynamic equipment allocation mechanism is more effective in coordinating equipment resources under larger-scale operational conditions. Compared with directly solving the model using the MATLAB integer linear programming solver, the proposed algorithm lowers the total operating cost of the terminal by 19.1%. Compared with the standard genetic algorithm, it shortens the average solution time by 33.5% and improves the average solution quality by 37.62%, which indicates its superior stability and solution accuracy. An efficiency-oriented and environmentally friendly decision-making approach can be provided for equipment configuration in rail-water intermodal transport container terminals. By dynamically allocating equipment quantities, the rail-ship direct transfer capability can be enhanced and yard congestion and storage pressure can be alleviated.

More>
2026, 26(9): 246-264. doi: 10.19818/j.cnki.1671-1637.2026.287